8th semester
AAU³ - Self-balancing Cube
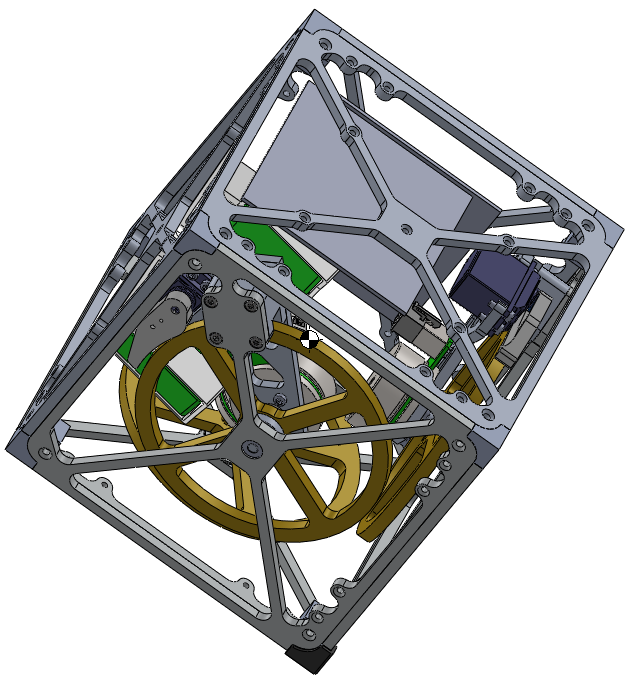
The AAU³ extends the Cubli concept into three dimensions. Three reaction wheels control the angular motion of a cube balanced on its corner; the project covered the physical and electrical design as well as system modelling.
A Linear Quadratic Regulator was designed for the model and verified in simulation. A Kalman decomposition was used to address an uncontrollable state. The completed prototype achieved an edge balance, providing a basis for further physical control work.